UGA partners with UW–Madison on $15M rural autonomous vehicle initiative
UGA Today highlights the university's role in the TRAVELS Center, a UW–Madison-led initiative supported by a $15 million U.S. Department of Transportation grant. Handong Yao leads UGA's interdisciplinary team, which will receive approximately $3.6 million to advance autonomous transportation in rural Georgia. The center's work aims to improve transportation access, safety, and efficiency for rural and tribal communities.
NHTSA Deputy Administrator visits UGA's Future Mobility Living Lab
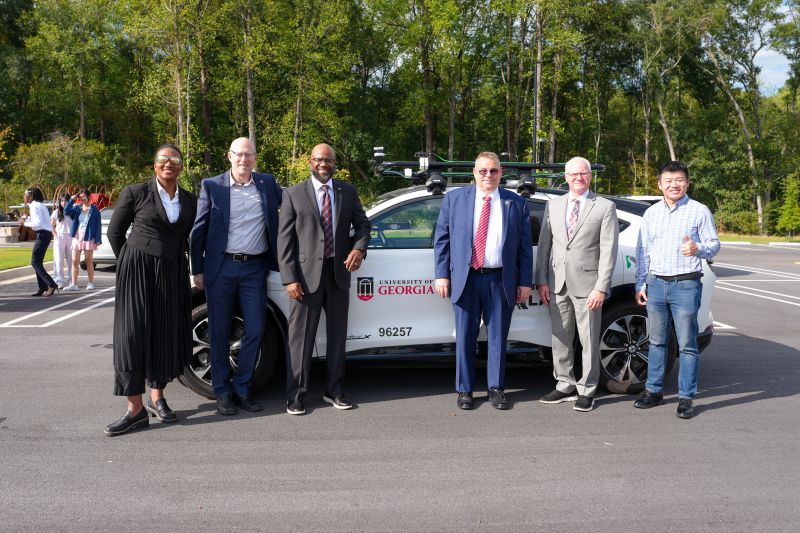
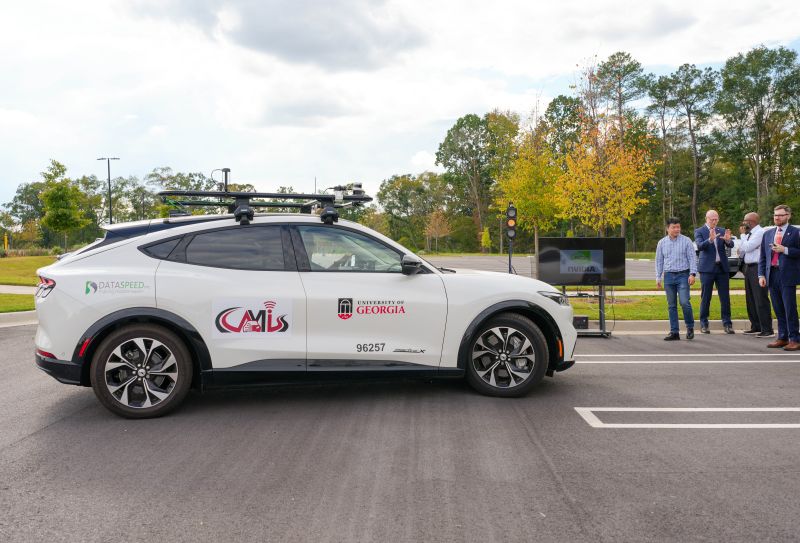
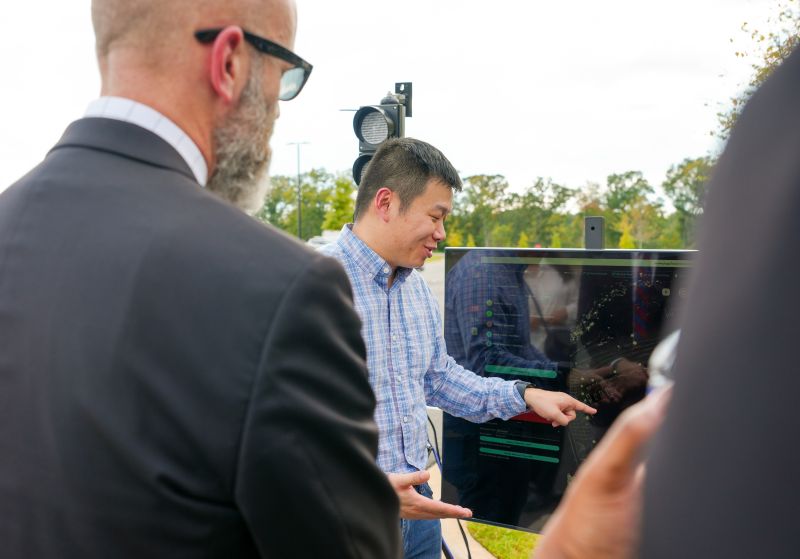
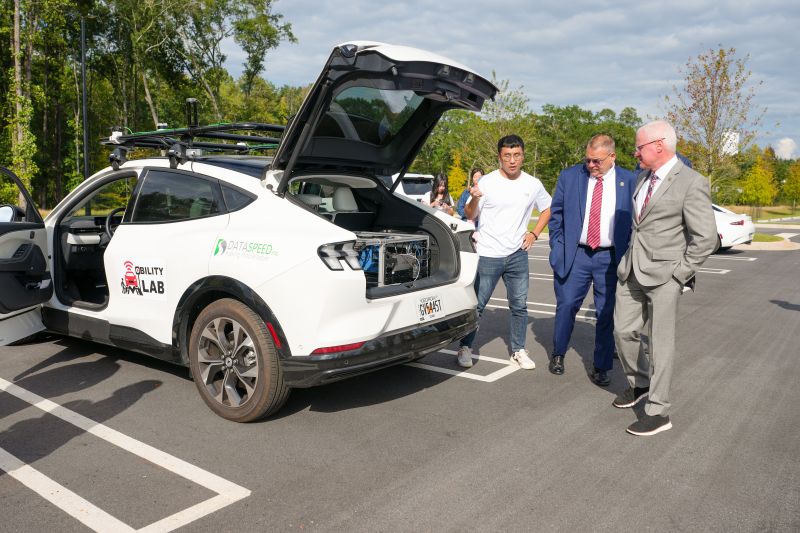
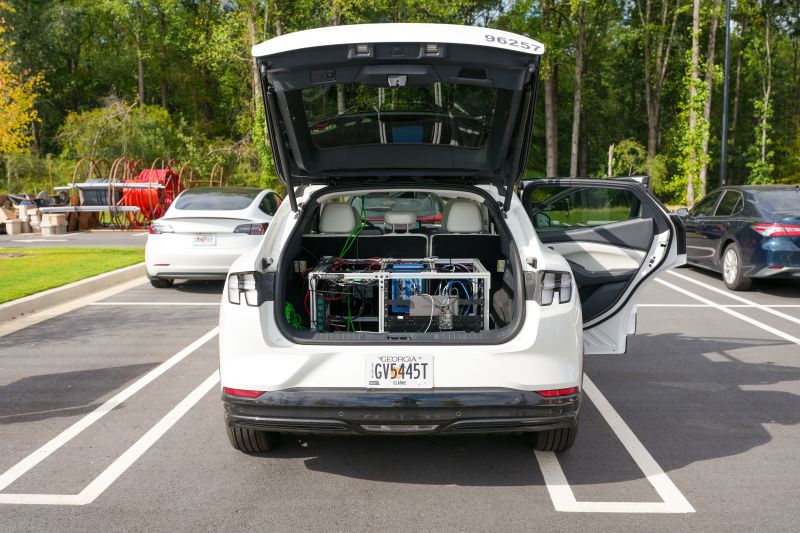
UGA researchers briefed Lee White, Deputy Administrator of the National Highway Traffic Safety Administration (NHTSA), on a USDOT-funded rural autonomous vehicle project. Handong Yao, Qianwen (Cami) Li, Haijian Sun, and the Future Mobility Living Lab team presented their work and demonstrated an autonomous vehicle. The Georgia Network for Electric Mobility published video and photo highlights of the visit on October 27, 2026.
Our rural AV route viewer brings together a Lanelet2 HD map and LiDAR point cloud from Hawkinsville, Georgia. The public map-data release supports interactive exploration of the route and its infrastructure challenges.
Rural AV evidence hub updated with interactive synthesis
Version 2.9 of our TRAVELS Rural Autonomous Vehicle literature-review website adds an interactive synthesis of research evidence, field-pilot findings, and deployment implications, with guided and advanced reading modes.
Pulaski County field visit advances rural AV planning
Handong Yao's UGA team met with local officials in Pulaski County to discuss a demonstration route connecting residential areas with the regional hospital. The visit also included data collection for high-definition mapping.
Our field-experiment study, Investigating the car-following behavior of electric vehicles with one-pedal driving, is published open access in Communications in Transportation Research. It examines how pedal mode interacts with manual driving and adaptive cruise control.
Our EV platoon dataset is available through ETS-Data, with synchronized 10 Hz vehicle trajectories collected under one-pedal and two-pedal driving, manual control, and adaptive cruise control.
Tianle Zhu shares rural-road AV readiness research
Tianle Zhu presented research on evaluating rural road infrastructure for commercial low-level autonomous vehicles at the Southeast Annual Symposium on Freight and Mobility. The related study by Tianle Zhu, Haohua Que, and Handong Yao was also accepted at ASCE ICTD 2026.
The ICTD 2025 poster programme featured studies coauthored by Handong Yao on electric-bus data and automated-vehicle interactions with traffic signs. Tianle Zhu was listed as the presenter of the electric-bus study, and Xuan Wang as primary author of the traffic-sign study.
Handong Yao shared research on safety-aware integrated prediction and planning for connected and automated vehicles at the 2025 Safe Mobility Conference in Madison, Wisconsin.
UGA Today highlights collaborative driving-safety research
UGA Today featured research coauthored by Handong Yao that connects traffic prediction and vehicle-motion planning to improve autonomous-driving safety.
Two papers accepted at the WACV 2027 UrbanState Workshop
LOWP (Look Only Where You Plan for Real-Time End-to-End Urban Driving) and Sample-and-Verify (Greedy Decoding Hides Good Plans: Sample-and-Verify Planning for Vision-Language Driving Models) have been accepted at the UrbanState Workshop at WACV 2027.
Behavioral Analysis and Impact Assessment of Advanced Driver Assistance Systems' Interaction with Traffic Signs has been recommended for presentation at the TRB 2027 Annual Meeting.
Camera degradation research selected for a TRB 2027 poster
End-to-End Automated Driving Under Camera Degradation: Planning Tolerance Thresholds and Closed-Loop Evidence has been selected for a poster presentation at the TRB 2027 Annual Meeting.
Our supported Capstone team, Infrastructure Evaluation Tool for Production Autonomous Vehicles with Cameras and GPS Devices, received the 2026 Manufactured System or Process Design Award.