Year in review
2026 at the
Mobility Lab.
Papers, projects, data, and stories from our 2026, gathered from the lab’s news and publications. Updated through Oct 29, 2026.
- Papers in 2026
- 10
- Accepted for 2027
- 6
- New funding to UGA
- $3.6M
- UGA’s share of the $15M TRAVELS Center
- Active projects
- 5
- USDOT · USDOT CR2C2 · FHWA · UGA Data Dawg
- Data and resource releases
- 3
- Lab stories
- 17
Month by month
The year
as it happened.
April
- Apr 15Tianle Zhu shares rural-road AV readiness researchTalks & fieldwork
- Apr 24EV platoon dataset published on ETS-DataData & resources
June
- Jun 30One-pedal driving study published in CTRPapers & awards
July
- Jul 13Pulaski County field visit advances rural AV planningTalks & fieldwork
August
- Aug 8Rural AV evidence hub updated with interactive synthesisData & resources
- AugHawkinsville HD map and point-cloud data releasedData & resources
October
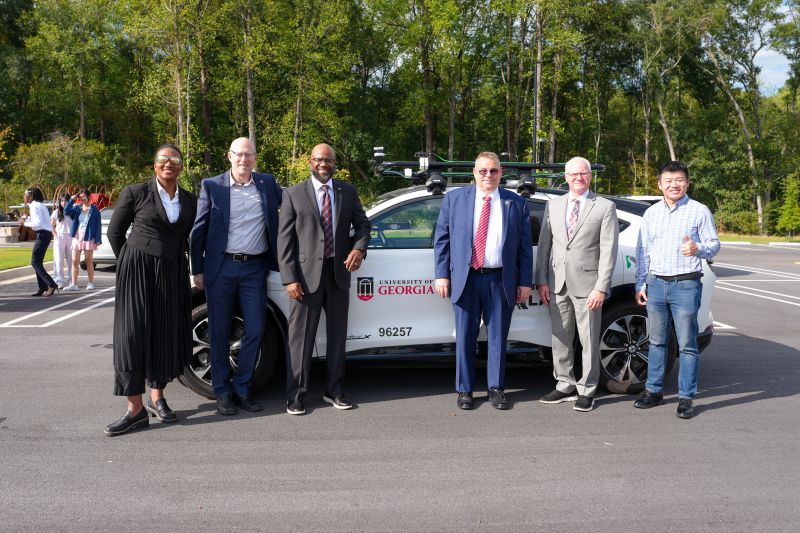
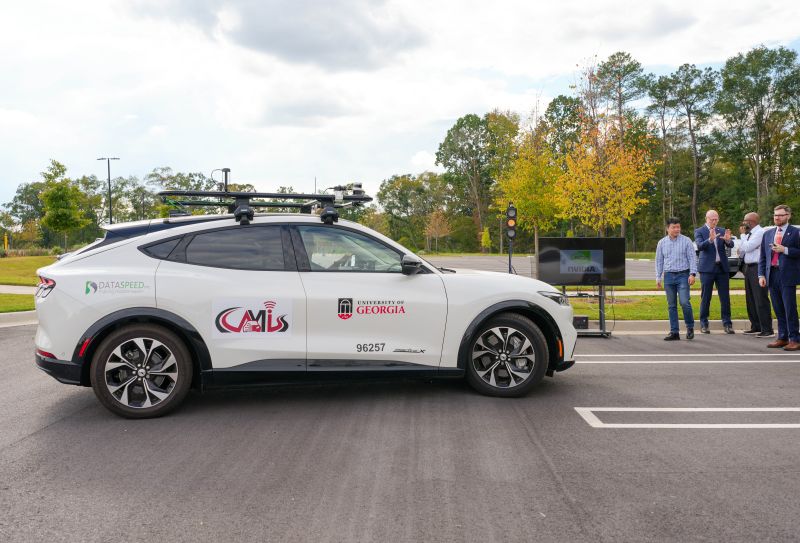
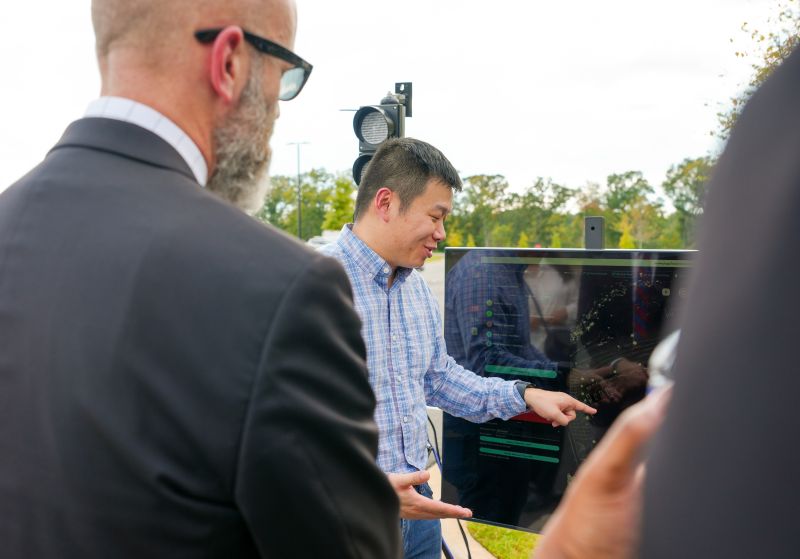
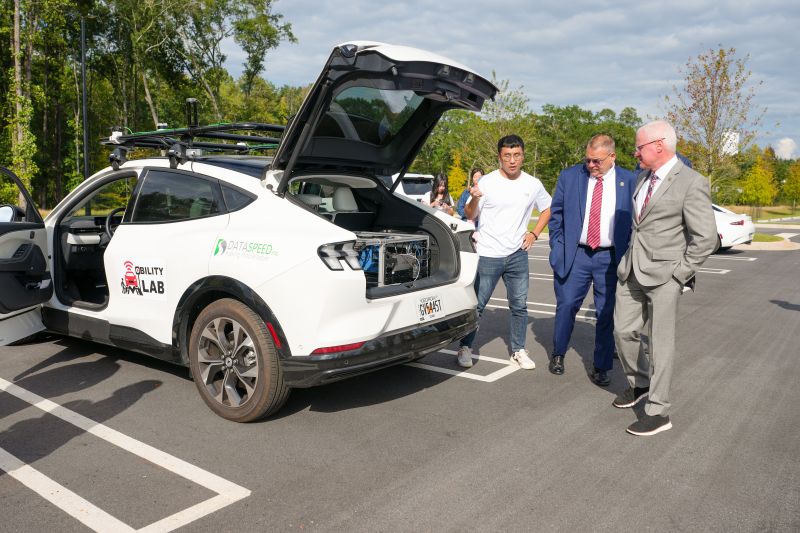
- Oct 27NHTSA Deputy Administrator visits UGA's Future Mobility Living LabIn the media
- Oct 29UGA partners with UW–Madison on $15M rural autonomous vehicle initiativeIn the media
Papers & awards
- Two papers accepted at the WACV 2027 UrbanState Workshop
- Two papers accepted at WACV 2027
- ADAS and traffic signs at TRB 2027
- Camera degradation research selected for a TRB 2027 poster
- CABLE accepted at IEEE SMC 2026
- Three papers accepted at IROS 2026
- Capstone team earns a design award
- MotiMem accepted at WCCI / IJCNN 2026
- MACE accepted at ICRA 2026
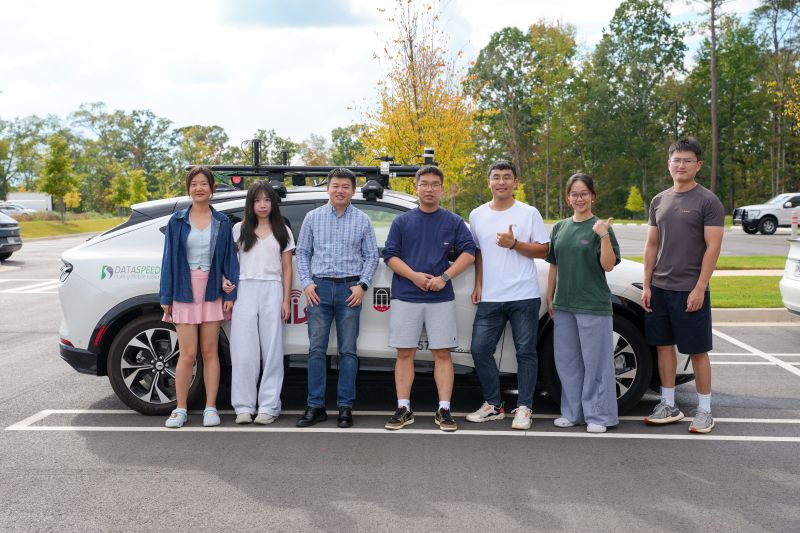
Photos
Publications
16 papers,
9 venues.
- WACV
- WACVW
- TRB
- SMC
- IROS
- WCCI
- ICRA
- ICTD
- CTR
Accepted for 2027
- DriveDegrade When Does Corruption Break the Plan? A Degradation-Tolerance Benchmark for Camera-Only End-to-End DrivingWACV 2027
- FALCON FPGA-Accelerated Latency-Certifiable Occupancy Networks for Camera-Based Autonomous DrivingWACV 2027
- LOWP Look Only Where You Plan for Real-Time End-to-End Urban DrivingWACVW 2027
- Sample-and-Verify Greedy Decoding Hides Good Plans: Sample-and-Verify Planning for Vision-Language Driving ModelsWACVW 2027
- Behavioral Analysis and Impact Assessment of Advanced Driver Assistance Systems' Interaction with Traffic SignsTRB 2027
- End-to-End Automated Driving Under Camera Degradation: Planning Tolerance Thresholds and Closed-Loop EvidenceTRB 2027
In 2026
- CABLE Cloud-Assisted Bandwidth-efficient LMM-based Encoding for V2X SystemsSMC 2026
- SenseExpo Spatial Exploration and Navigation Via Scene Estimation from Expeditious Predictive OperatorsIROS 2026
- ACESplat Accelerated 3D Gaussian Scene Regression Via RGB and Poses OnlyIROS 2026
- DinoLink A Token-Centric Representation Compression Framework for Bandwidth-Constrained Collaborative V2X PerceptionIROS 2026
- MotiMem Motion-Aware Approximate Memory for Energy-Efficient Neural Perception in Autonomous VehiclesWCCI 2026
- MACE Mixture-of-Experts Accelerated Coordinate Encoding for Large-Scale Scene Localization and RenderingICRA 2026
- Road Infrastructure Readiness Evaluation for Commercial Low-Level Autonomous VehiclesICTD 2026
- Investigating the car-following behavior of electric vehicles with one-pedal drivingCTR 2026
- Investigating the Car Following Behavior of Electric Vehicles with One-Pedal Driving Through Field ExperimentsTRB 2026
- Modeling Autonomous Driving Systems-Equipped Vehicle Interactions with Traffic SignsTRB 2026
Research threads
Where the work
went this year.
- Robust driving3 papers · 3 stories
- Onboard perception3 papers · 3 stories
- V2X perception2 papers · 2 stories
- 3D scenes & robots3 papers · 2 stories
- Vehicle behavior4 papers · 3 stories
- Rural roads1 paper · 7 stories